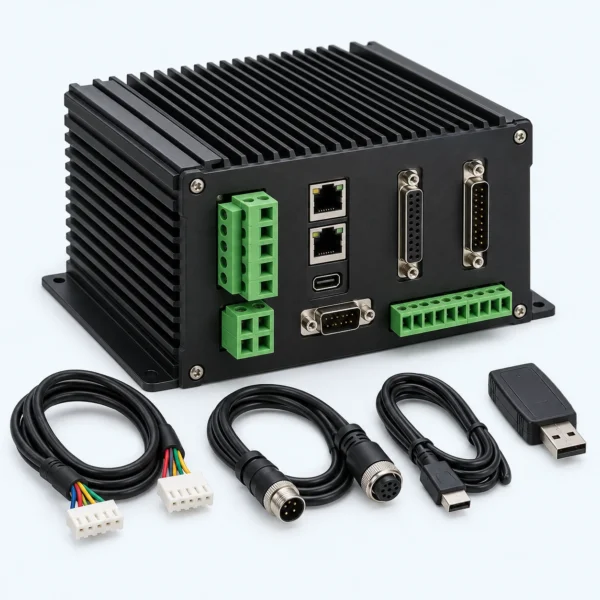
Servo Drive for Robot Joint Motors
A servo drive controls motor current, torque, speed, and position using commands from a host controller and feedback from the axis. This RFQ page supports selection for robot joints, compact actuators, test systems, and other motion axes. It does not represent a fixed drive model or guarantee compatibility with an unspecified motor. RobotPiece reviews the motor electrical data, feedback device, power system, communications, safety functions, form factor, and commissioning environment before proposing a suitable drive.
An EtherCAT servo drive and a CANopen servo drive may serve similar motion objectives while differing in network architecture, synchronization, profiles, diagnostics, and master requirements. The phrase servo drive controller can also refer to different boundaries between the drive, motion controller, and host. For a robot joint motor drive, confirm which control loops run locally, what command modes are required, and how multiple axes coordinate. Protocol names alone do not establish electrical connectors, supported profiles, firmware features, or interoperability.
Selection and Engineering Requirements

An EtherCAT servo drive should be assessed with the required synchronization and master behavior, while a CANopen servo drive must be checked against the intended device profile and object mapping. A servo drive controller may combine different motion functions depending on the configuration. For a robot joint motor drive, motor data, feedback, bus voltage, regeneration, firmware, and command modes remain part of the same compatibility review.
The inquiry should also distinguish required functions from optional commissioning, cabling, or motion-control scope.
Provide the motor type and available motor data: phase resistance, phase inductance, torque or force constant, back-EMF constant, pole-pair count, continuous and peak current, maximum electrical speed, temperature sensing, and any brake characteristics. Include the actual feedback type and interface, such as incremental, absolute, Hall, resolver, or another device, together with resolution and communication details. If the motor is still being selected, state that clearly so the drive and motor can be evaluated together.
Power information should include the DC bus or AC input architecture, normal and maximum voltage, supply current limits, regeneration strategy, braking needs, and shared-bus arrangement. Describe the control modes, command update rate, bandwidth objective, network protocol and master, synchronization needs, I/O, safety expectations, and fault-handling behavior. Mechanical requirements include the available board or enclosure space, cooling, mounting, connector direction, cable lengths, grounding, and electromagnetic environment.
Engineering Reference
This network technology overview explains communication and synchronization. It is background for specifying a host interface, not evidence that a proposed drive supports a particular master, profile, or firmware feature. Review the technical background.
Scope and Configuration to Confirm
The quotation may cover a board-level drive or an enclosed unit. Power supply, brake resistor, communication interface, feedback adapter, connectors, mating plugs, cables, motor temperature interface, commissioning software, parameter files, and programming tools are separate unless listed. Confirm whether firmware, protocol profiles, safety functions, and documentation required by the host system are included in the proposed configuration.
Current specifications are confirmed per requirement. RobotPiece does not claim plug-and-play operation based only on motor power or protocol. The exact motor, encoder, brake, bus voltage, network master, firmware, cabling, and control method must be checked. Any product-type illustration is a category reference rather than an image of the final supplied drive.
Inquiry Checklist
- Motor datasheet and winding data, current requirements, speed, and temperature sensor
- Feedback make or type, electrical interface, resolution, and commutation information
- Power architecture, voltage range, current limits, regeneration, and braking strategy
- Control modes, network protocol, host or master, update rate, and synchronization
- Board or enclosure envelope, cooling, connectors, grounding, cabling, and environment
- Axis count, prototype and production quantities, destination, schedule, and support needs
Send the motor data and control architecture through the RobotPiece contact page. Related motion-control products are grouped in the Drives category.
Frequently Asked Questions
Can I confirm a servo drive from the motor’s rated power?
No. Rated power does not define current dynamics, bus voltage, winding, electrical speed, feedback, braking, or duty. The motor data and real operating profile are needed to check electrical and control compatibility.
Does selecting EtherCAT or CANopen guarantee compatibility with my controller?
No. The network name is only the starting point. The device profile, modes, object or process data, synchronization, firmware, connector, wiring, and master behavior must be confirmed for the intended system.
Image note: the cover is a conceptual product-type illustration, not a photograph of a confirmed model. Actual appearance, dimensions, connectors and supplied items must be confirmed in the quotation.
